Skip to content
No results
  • Frontier Radar
  • Courses
  • Open Source Projects
  • Engineering
  • English
    • 中文
    • 日本語
NoteFlowAI brand logo
Physical AI Lab
  • Frontier Radar
  • Courses
  • Open Source Projects
  • Engineering
  • English
    • 中文
    • 日本語
Sign in
NoteFlowAI brand logo
Physical AI Lab
Sign in
Text-free abstract artwork on a pale violet background: four identical outlined circles with filled centres in a row, joined by a straight line; a small cluster of four linked circles at the top left; and a large pale disc in the top-right and bottom-left corners.
  • Engineering

Keeping members-only content out of AI answers and read-aloud audio: how AI Chat for Amazon Bedrock gets “the text a guest sees”

Pinned source and synthetic tests: AI Chat for Amazon Bedrock renders posts signed out, drops blocks with visibility rules and skips noindex pages.
  • October 7, 2026
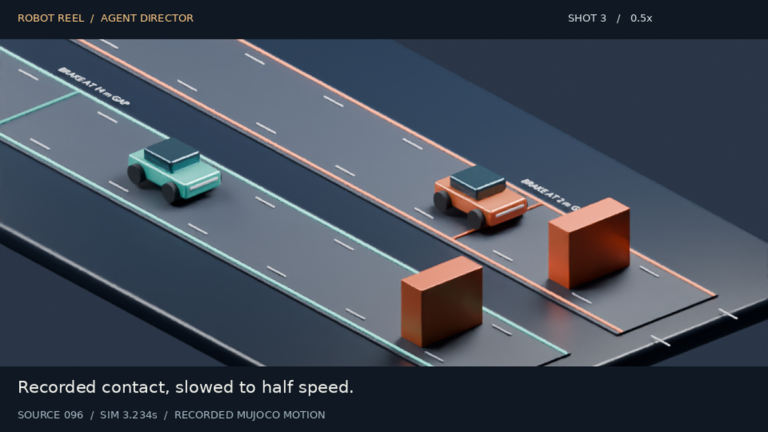
Original project poster: on a dark background, an oblique overhead view of two parallel lanes. The left lane has teal edge lines and a teal car heading towards an orange block ahead of it; the right lane has orange edge lines and an orange car behind another orange block. Small slanted labels on the lanes read “BRAKE AT 14 m GAP” and “BRAKE AT 2 m G…”, the latter partly hidden by the block in the right lane. The top left reads “ROBOT REEL / AGENT DIRECTOR” and the top right “SHOT 3 / 0.5x”; the caption at the bottom reads “Recorded contact, slowed to half speed.”, and small text below it “SOURCE 096 / SIM 3.234s / RECORDED MUJOCO MOTION”.
  • Open Source Projects

Cutting a robot simulation recording into a checkable film: Robot Reel’s agent director and its storyboard contract

Robot Reel’s agent director checks that a storyboard covers a recording with no gaps, then replays it in Blender: 4 shots, 180 source samples in 210 frames.

  • October 7, 2026
Conceptual illustration: a magnifying glass at top left; across the middle, three pale circles side by side, each holding an outlined diamond above a short horizontal line and separated by thin vertical lines; two large pale circles in the background at top right and bottom left; no text, numbers or charts.
  • Engineering

Why a cheaper bracket was still rejected: checking 3-axis milling setups, holes, screw clearance and unit-cost estimates on the B-Rep

pai-design-workbench 3-axis DFM: a compact bracket estimated at 14.69 EUR meets a 16 EUR target, yet ribs block two M5 holes and it fails hole-edge distance.

  • October 6, 2026
Conceptual illustration: on a pale background, a closed oval ring carrying four hollow circles with dots, standing for repeated proposals, checks and evaluations; a pale disc with a filled dot in the centre of the ring; a magnifying glass shape at the upper left, and two large pale discs cut off by the edges at the top right and bottom left; no text.
  • Open Source Projects

Running a hill-climbing loop with EvalArc: keep useful changes, roll back an overfitted proposal

evalarc hillclimb-run loops your evaluate and propose commands; in a scripted example it rolls back pasted case answers and an overfitted edit.

  • October 6, 2026
Course cover · 1.4
  • Courses

Physical AI Lab 1.4: A Map of Simulators — Counting the Cost of the Timestep, Finding Where Contact Splits Two Runs, and Pinning Three Speed-ups to Their Baselines

A Map of Simulators — Counting the Cost of the Timestep, Finding Where Contact Splits Two Runs, and Pinning Three Speed-ups to Their Baselines. English video, reading, self-checks and sources in one lesson, updated 2026-10-06.

  • October 6, 2026
Course cover · 1.3
  • Courses

Physical AI Lab 1.3: Sensors — Working Out Pixels, Depth Range and Grip Force for One Cup

Public quiz with full explanations. Sign in to pick depth modes, predict slip in a grasp log and review a spliced sensor plan, with worked solutions.

  • October 6, 2026
Course cover · 1.2
  • Courses

Physical AI Lab 1.2: PID and Control Rate — Computing the Three Terms by Hand, Then Turning Rates into Periods

Public quiz with full explanations. Sign in to work a PID log with a disturbance, compute response metrics and review a control-rate memo.

  • October 6, 2026
Original project poster: on a dark green gradient background, a rounded-square icon in the centre shows the letter P with a wireframe cube. Below it, the Chinese title “机器人工作单元提速:AI 设计,物理验证” (Speeding up a robot workcell: AI design, physics verification) and the subtitle “MuJoCo 发现碰撞 → AI 修正 → CalculiX 否决几何最优 → 物理寻优 → 签名发布” (MuJoCo finds a collision → AI fixes it → CalculiX rejects the geometry-only optimum → physics-aware optimisation → signed release). Beneath are six rounded labels: “MuJoCo 3.14 刚体动力学” (rigid-body dynamics), “Gmsh + CalculiX 2.21”, “GP 代理模型 + NSGA-II” (GP surrogate), “Kiro 2.27 · claude-opus-5.5”, “EvalArc 独立对照” (independent comparison), “签名发布包” (signed release package). Small text at the bottom: “全部结果实时生成,未剪辑;静止的等待画面已加速” (all results generated live, unedited; static waits sped up).
  • Open Source Projects

Carrying an accepted CAD part into a robot arm simulation: mass checks and portable MJCF and OpenUSD exports

pai-design-workbench mounts only an accepted, digest-checked CAD part on a MuJoCo arm, requires mesh mass within 3% of B-Rep, then exports MJCF and OpenUSD.

  • October 5, 2026
Abstract conceptual illustration with no text: two parallel groups of circles and lines, suggesting two ways of executing that can be compared side by side when the outcome is the same.
  • Frontier Radar

Frontier Radar | Is Success All You Need?: two VLAs with similar success rates can succeed in very different ways

LIBERO-Spatial, camera perturbation: π0.5 and VLANeXt reach 69.7%/68.0% TSR, yet π0.5’s successful runs show 24.1% more jerk vs 3.2% (authors report).

  • October 5, 2026
Conceptual illustration: an abstract geometric composition of parallel circles and lines evoking a comparison of estimate and measurement, with no text, numbers or charts.
  • Engineering

Checking an agent’s physics estimate against held-out solver results: the evaluation passed, but the height trend was backwards

The model returns only three bounded exponents; a template builds the estimator. One run: median 0.114, worst 0.321, Spearman 0.95, passed, height sign wrong.

  • October 5, 2026
Course cover · 1.1
  • Courses

Physical AI Lab 1.1: Coordinate Frames and Kinematics — Working Out by Hand How a Two-Link Arm Reaches the Cup

Public quiz with full explanations. Sign in to convert cups from a new camera mount, audit a fictional IK solver log and score solutions by the paper’s cost.

  • October 5, 2026
Course cover · 0.6
  • Courses

Physical AI Lab 0.6: How to Judge Robot News — Tracing Each Question Back to a Sentence in the Source

Public quiz with full explanations. Sign in to trace a number through four retellings, build a timeline and status card, and review four headlines.

  • October 4, 2026
Prev
1 2 3 4 5 6
Next
© 2026 Physical AI Lab
  • Privacy Policy

Physical AI Lab · AI Assistant

AI
Hi! I'm the Physical AI Lab's AI assistant. Ask me anything about robotics, embodied AI or the course.

Sign in to chat with the assistant.

Sign in
Powered by Amazon Bedrock