Skip to content
No results
  • Frontier Radar
  • Courses
  • Open Source Projects
  • Engineering
  • English
    • 中文
    • 日本語
NoteFlowAI brand logo
Physical AI Lab
  • Frontier Radar
  • Courses
  • Open Source Projects
  • Engineering
  • English
    • 中文
    • 日本語
Sign in
NoteFlowAI brand logo
Physical AI Lab
Sign in
Course cover · 0.5
  • Courses

Physical AI Lab 0.5: The Humanoid Robot Boom — Sorting One Passage of Tesla’s Quarterly Update into Demo, Prototype, Production and the Job

Public quiz with full explanations. Sign in to split a demo log, compute one shift's uptime three ways and review a purchasing memo, with worked solutions.
  • October 4, 2026
Abstract conceptual illustration with no text: two large pale-blue circles on a light background, four stacked translucent planes in the center, each with a short line mark, and a fixed-base robot-arm icon at the top left.
  • Frontier Radar

Frontier Radar | ReCo: make a walking policy’s command response predictable first, so MPC can coordinate a quadruped’s base and arm

ReCo trains a walking policy to respond repeatably and gives MPC a fitted response model; authors report 28.7%/27.4% lower RMSE and 75/100 successes in sim.

  • October 4, 2026
Conceptual illustration: across the middle, several identical rings evenly spaced on a horizontal line, each with a solid dot at its center, standing for a case passing through packing, remote solving, verification and checks; at top left, an outlined stack of three server-rack-like bars standing for the compute infrastructure; pale large circles in the background; no text.
  • Open Source Projects

Carrying a pinned OpenFOAM case to AWS Batch: hashed results, two meshes and a drag comparison with the local run

pai-design-workbench runs each OpenFOAM v2512 case as a Batch job, verifies hashes and version, then four checks. Candidate Cd: 0.22945 local, 0.22926 Batch.

  • October 4, 2026
Course cover · 0.4
  • Courses

Physical AI Lab 0.4: Ten Thousand Tries in a Virtual World — Putting the Conditions Back on Three Simulation Numbers

Public quiz with full explanations. Sign in to choose a parallel set-up, separate three kinds of training time and review a sim-to-real plan.

  • October 4, 2026
Conceptual illustration: in the top-left corner, a central circle joined by three lines to three small circles; across the middle, three identical circles side by side, each containing a diamond outline with a short horizontal line beneath it, separated by thin vertical lines; two large pale circles in the background; no text.
  • Engineering

Reviewing a skill means more than SKILL.md: checking scripts and references with dsh-skills-anywhere’s directory manifest

SKILL.md unchanged, scripts changed? dsh-skills-anywhere 0.9 hashes every file: compare exits 0, 1, 2; MCP loads reject changes; what a match cannot prove.

  • October 3, 2026
Conceptual illustration: on a light background, a line drawing of a robot arm at top left; in the centre, three outlined circles with dots sit on a pale ellipse, around a larger filled pale circle with a dot at its centre; two large pale background discs at top right and bottom left. There are no arrows.
  • Frontier Radar

Frontier Radar | Token-World: rolling out a world model in VLM token space to simulate VLA policies without RGB reconstruction

Token-World compresses Qwen3-VL tokens from 2560 to 16 channels and predicts there, no RGB; authors report r=0.794 vs 0.583 for Ctrl-World.

  • October 3, 2026
Text-free conceptual illustration: a magnifier at the top left, and five ringed circles with filled centres joined by a horizontal line over large pale background circles.
  • Open Source Projects

Trying Robot Reel on your own LeRobot episode: how the first-use trial kit times, reports and counts attempts

Run Robot Reel’s first-use trial on your own LeRobot episode: install, export, verify, time it, report. How reports are counted; the pinned record counts 0.

  • October 3, 2026
Conceptual illustration: a magnifying glass shape in the top-left corner; across the middle, four identical rings evenly spaced on a horizontal line, each with a solid dot at its center, standing for review steps taken in order; two large pale circles in the background; no text.
  • Open Source Projects

Handing off an EvalArc report folder: input copies, recorded options and the limits of evalarc verify

EvalArc's diff, eval-health and hillclimb-review save input copies and all options; evalarc verify recomputes offline. What exit codes 0, 1, 2 mean.

  • October 2, 2026
Conceptual illustration: on a light background, an abstract robot-arm line linking three joint circles, beside three tilted planes stacked on one another, suggesting the slow planning stream, the fast correction stream and the executed action that combines them.
  • Frontier Radar

Frontier Radar | DSDyn-VLA: when the target moves, a VLA has to close three gaps in perception, latency and control

DSDyn-VLA pairs a ~2–3 Hz optical-flow planner with ~30 Hz residual RL; authors report 49.0% real-robot success vs 8.4% (π0.5) and 38.1% (DynamicVLA).

  • October 2, 2026
Text-free conceptual illustration: a left-to-right timeline composition showing a chat request passing several checks before it reaches order data.
  • Engineering

“Package”, “returns” or “shipped” alone is not enough: how a WooCommerce chat assistant decides a message is about an order

AI Chat for Amazon Bedrock sends a customer’s orders to the model only if the question points at an order: 11 patterns, ownership checks, fields, blind spots.

  • October 2, 2026
Course cover · 0.3
  • Courses

Physical AI Lab 0.3: See, Think, Act — Putting Each Rate Back in Its Own System

The public quiz has full explanations. Sign in for a layered clock table, log-based collision diagnosis and evidence cards, with worked solutions and a rubric.

  • October 1, 2026
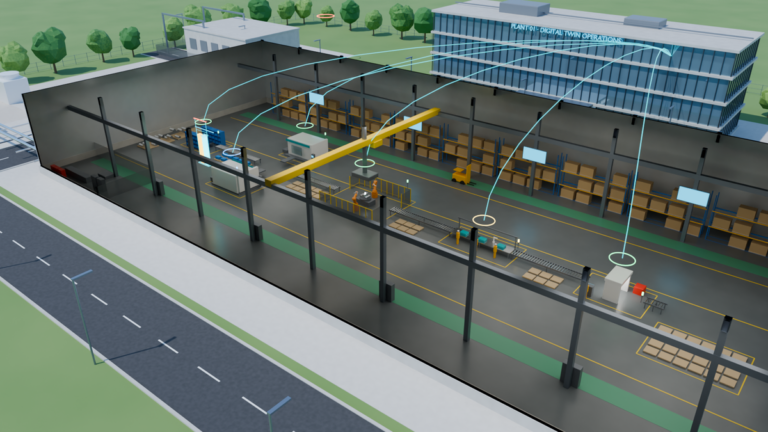
Factory Twin scene rendering from Robot Reel documentation, not paired-trial footage or a real-world photograph.
  • Engineering

Reviewing a factory digital twin’s decisions: paired runs, losing seeds included

Factory Twin Lab pairs closed-loop and shadow runs on identical disturbances: 0 vs 11 spindle failures over 12 pairs, yet output rose in 10 and fell in 2.

  • October 1, 2026
Prev
1 2 3 4 5 6
Next
© 2026 Physical AI Lab
  • Privacy Policy

Physical AI Lab · AI Assistant

AI
Hi! I'm the Physical AI Lab's AI assistant. Ask me anything about robotics, embodied AI or the course.

Sign in to chat with the assistant.

Sign in
Powered by Amazon Bedrock